From one drone to a fleet


Ground nodes mesh with each other, and the ground station bridges fleet telemetry to the cloud.
How it works
Every drone to one cloud
Drones and ground stations publish to an MQTT broker over TLS. There is no port forwarding on the drone side.
Capability tiers
Four tiers, one agent
The agent picks its tier from an explicit setting, the board profile, or the memory it finds. Each step up adds services on the same drone.
| Tier 1 | Tier 2 | Tier 3 | Tier 4 | |
|---|---|---|---|---|
| MAVLink proxy | ✓ | ✓ | ✓ | ✓ |
| REST API | ✓ | ✓ | ✓ | |
| Health monitoring | ✓ | ✓ | ✓ | |
| LAN discovery | ✓ | ✓ | ✓ | |
| Video pipeline | ✓ | ✓ | ||
| Long-range video link | ✓ | ✓ | ||
| Cloud relay | ✓ | ✓ | ||
| Peripherals manager | ✓ | ✓ | ||
| Vision host and models | ✓ |
MAVLink proxy
REST API
Health monitoring
LAN discovery
Video pipeline
Long-range video link
Cloud relay
Peripherals manager
Vision host and models
Dashboard
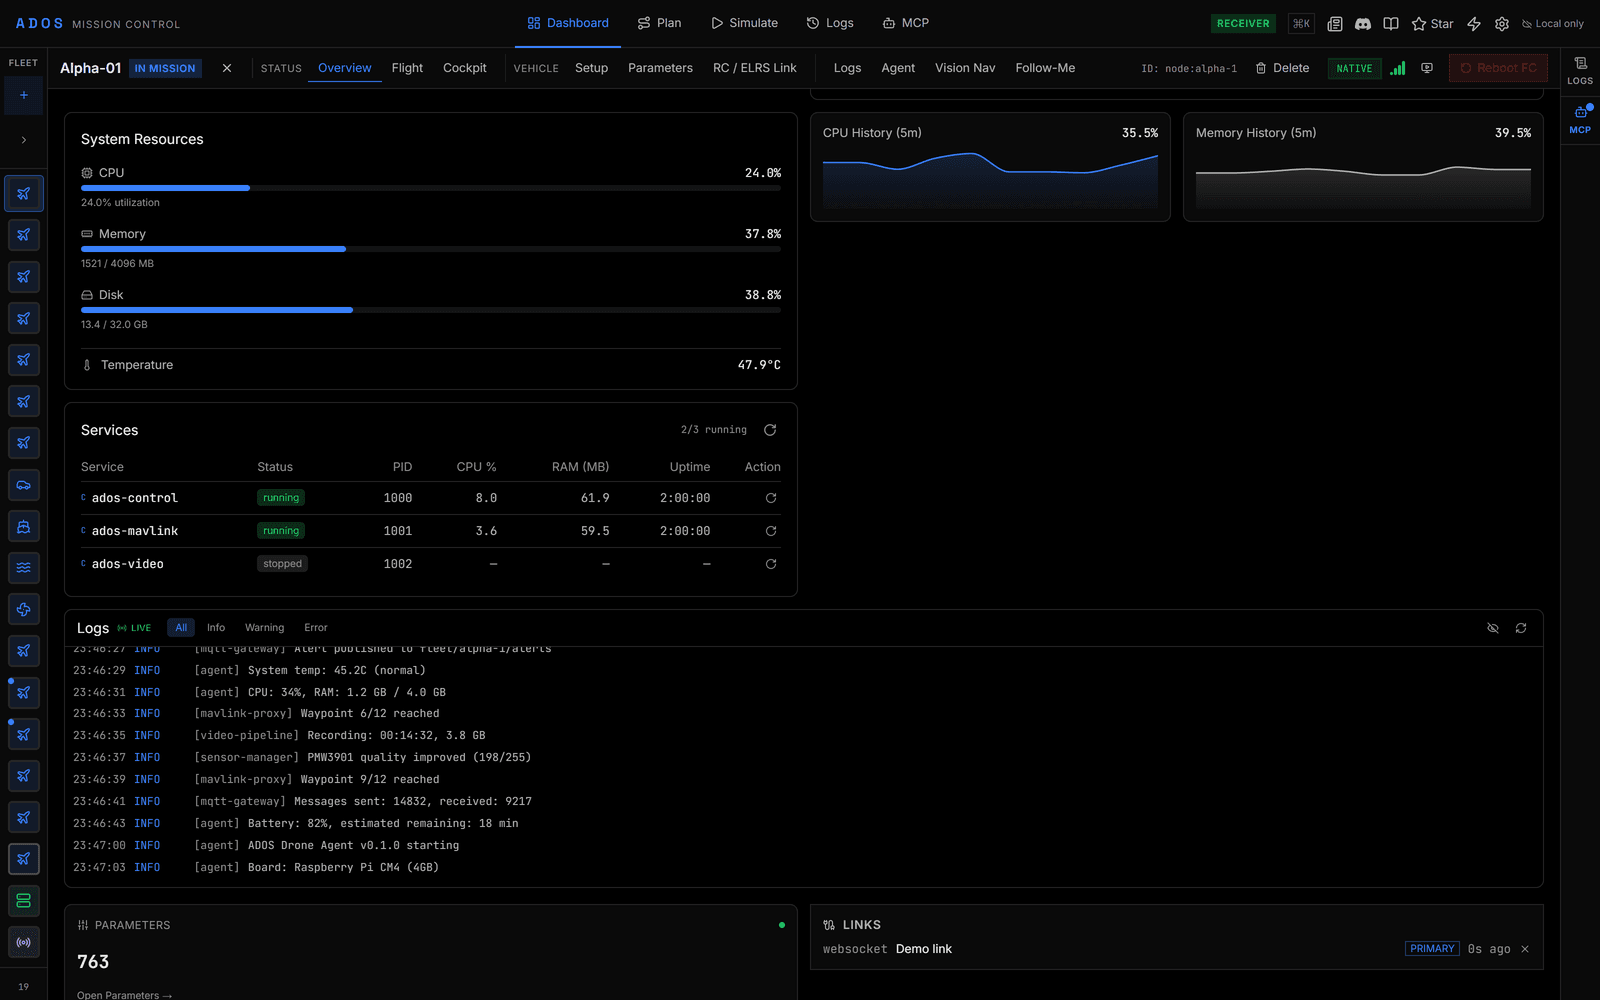
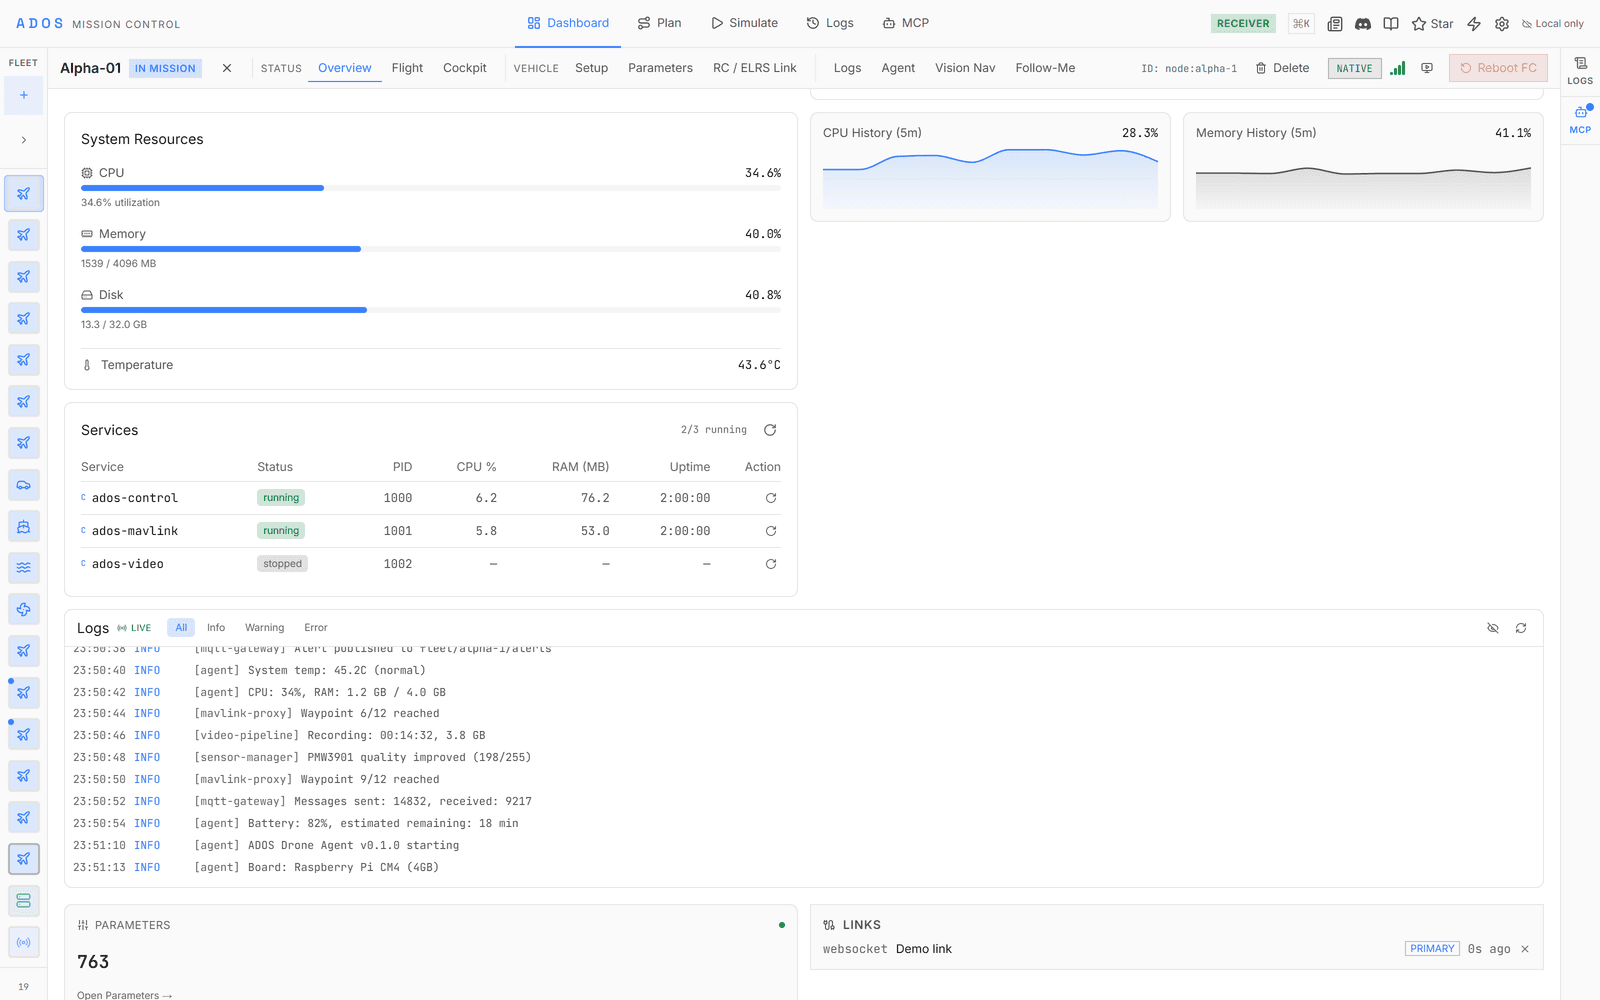
Run the fleet from a browser
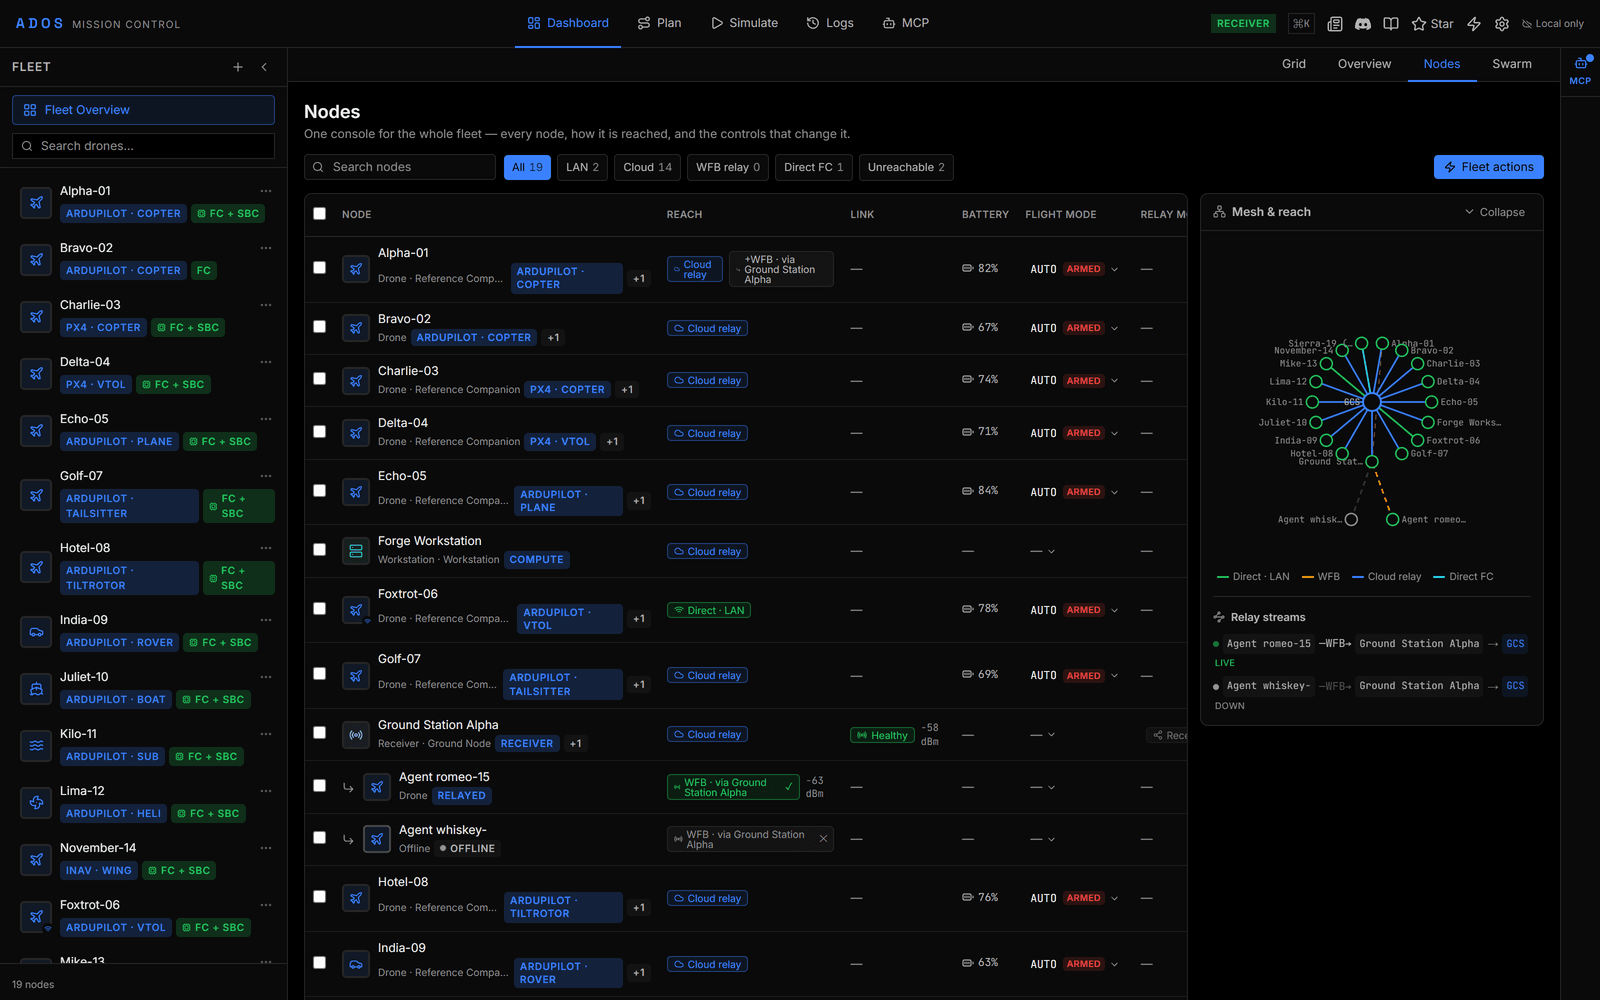
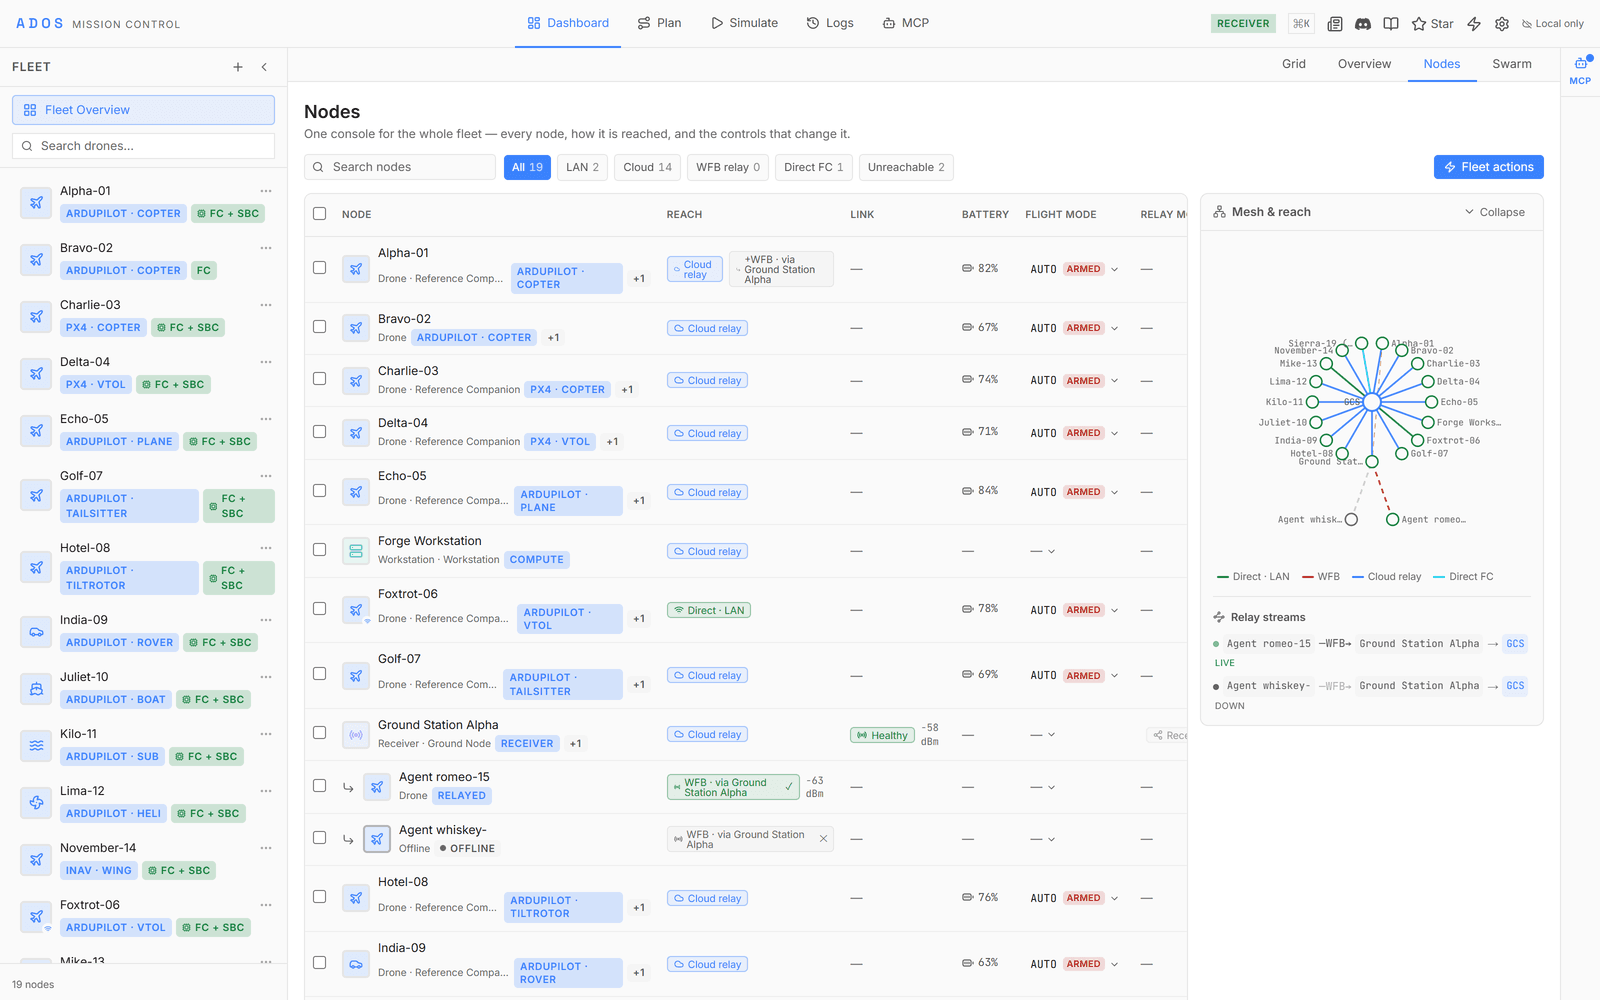
Every node Mission Control can reach, whether over the LAN, through a ground station's radio, through the cloud relay, or straight to a flight controller.
Every node and how it is reached
One table for drones, ground stations, and workstations, with the link each one is on and the mesh behind it.
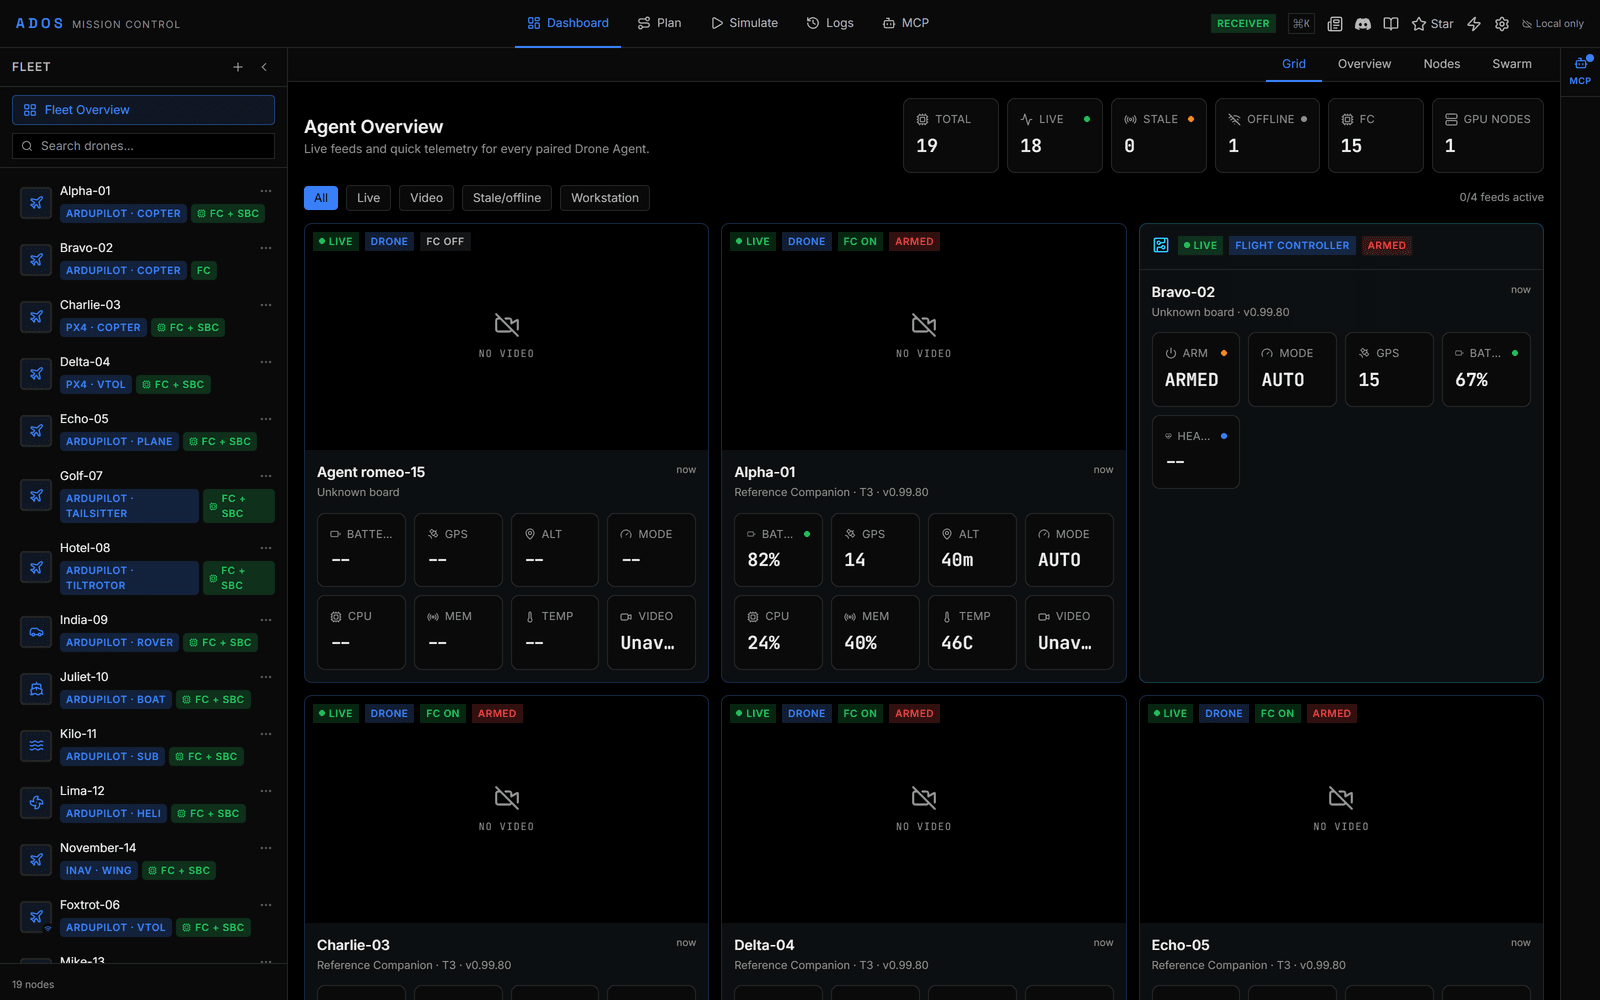
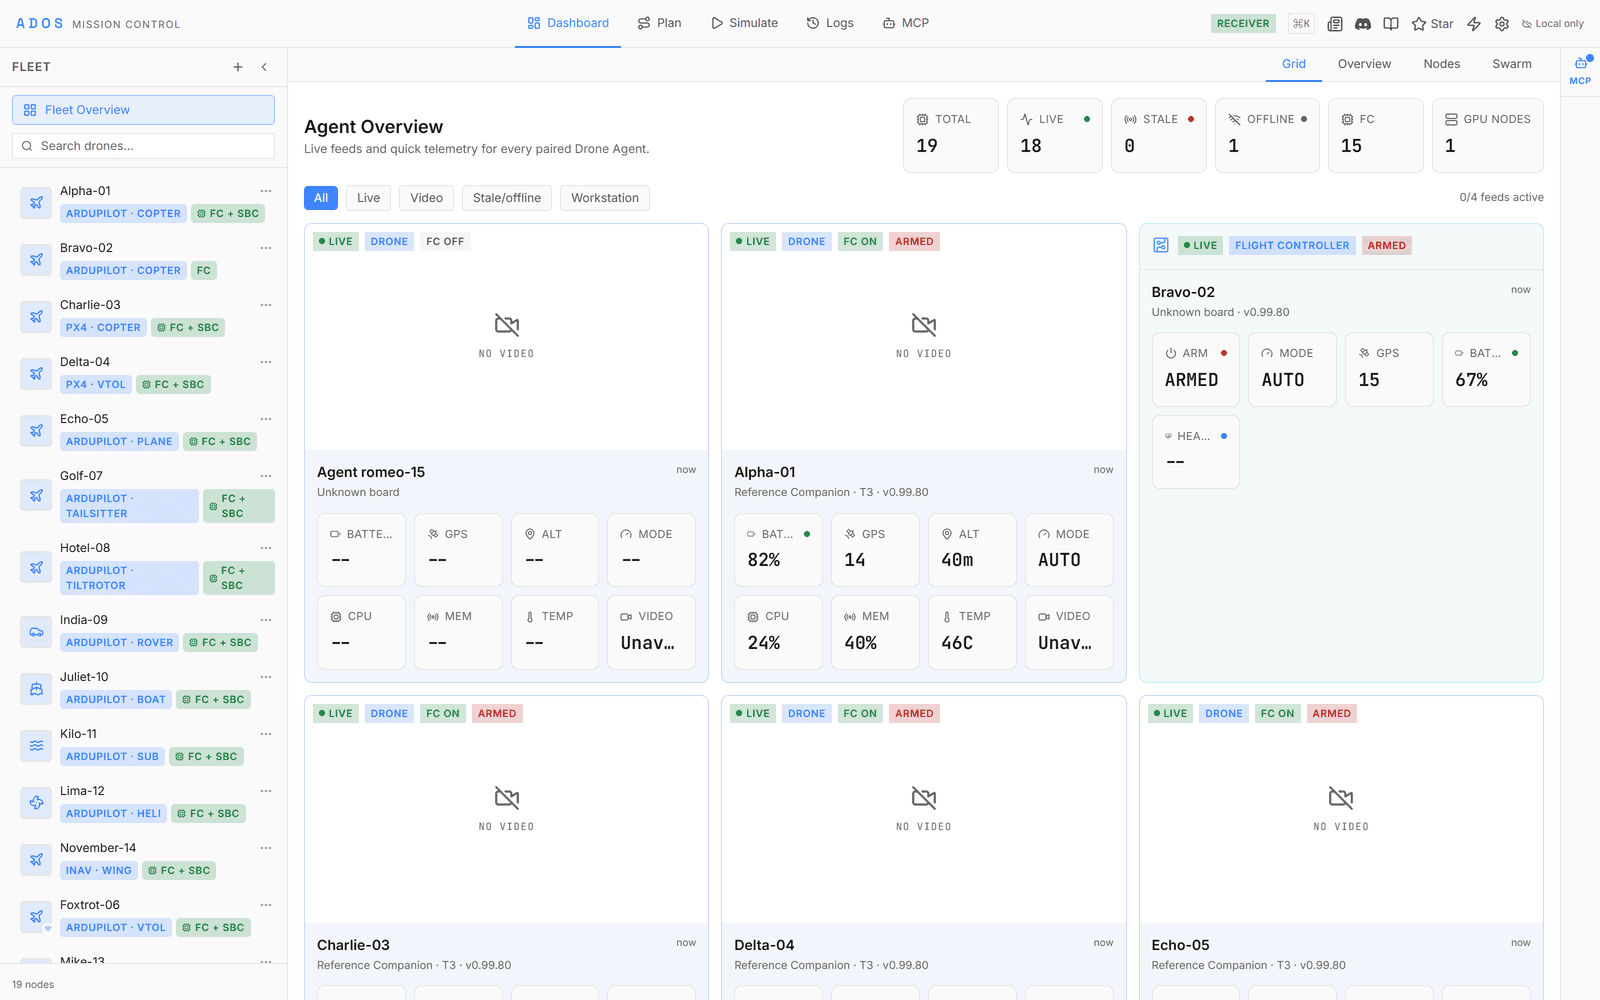
Live feeds and telemetry
A card per paired agent with its feed, battery, GPS, altitude, mode, and companion load.
Aircraft registry
Per-drone records: make, model, serial, registration, airworthiness, flight hours, and maintenance due.
Missions and logs
Plan and upload missions from the browser, follow them live, and keep a flight log for every flight.
Telemetry
MQTT at 2 Hz by default, and configurable. QoS 0 for MAVLink frames, QoS 1 for session signaling.
Flight reports
Totals for flights, hours, distance, and battery used, broken down per drone.
Transport
Built on MQTT
A bidirectional bus where every device signs in with its own identity and each message class gets the delivery guarantee it needs.
- Protocol
- MQTT over TLS
- Topics
- Per device
- QoS
- 0 for MAVLink frames, 1 for signaling
- Browser transport
- WebSocket
- Drone-side ports
- Zero forwarding
Bring your fleet online
Start with any MAVLink drone in Mission Control, then add a companion running the agent for cloud relay, video, and vision.
See the pricing