One console for the whole fleet.
REACH TYPES
Every node, however it connects.
A node can be reached four ways. The console shows which one is live, so you always know how you are talking to a drone before you send it a command. When none of the four applies, the node shows as unreachable.
| Data path | Typical use | |
|---|---|---|
| Local network | Direct over the LAN | Same network, lowest latency |
| Cloud relay | Through the cloud broker | Remote or across networks |
| Relayed over the radio | Through a paired ground node | A drone linked by radio, no IP of its own |
| Direct flight controller | Serial, USB, or a network link | A flight controller with no companion computer |
| Unreachable (state) | None of the four paths is live | Last known state, awaiting reconnection |
Local network
Cloud relay
Relayed over the radio
Direct flight controller
Unreachable (state)
MESH & REACH GRAPH
Not a flat list. A reach graph.
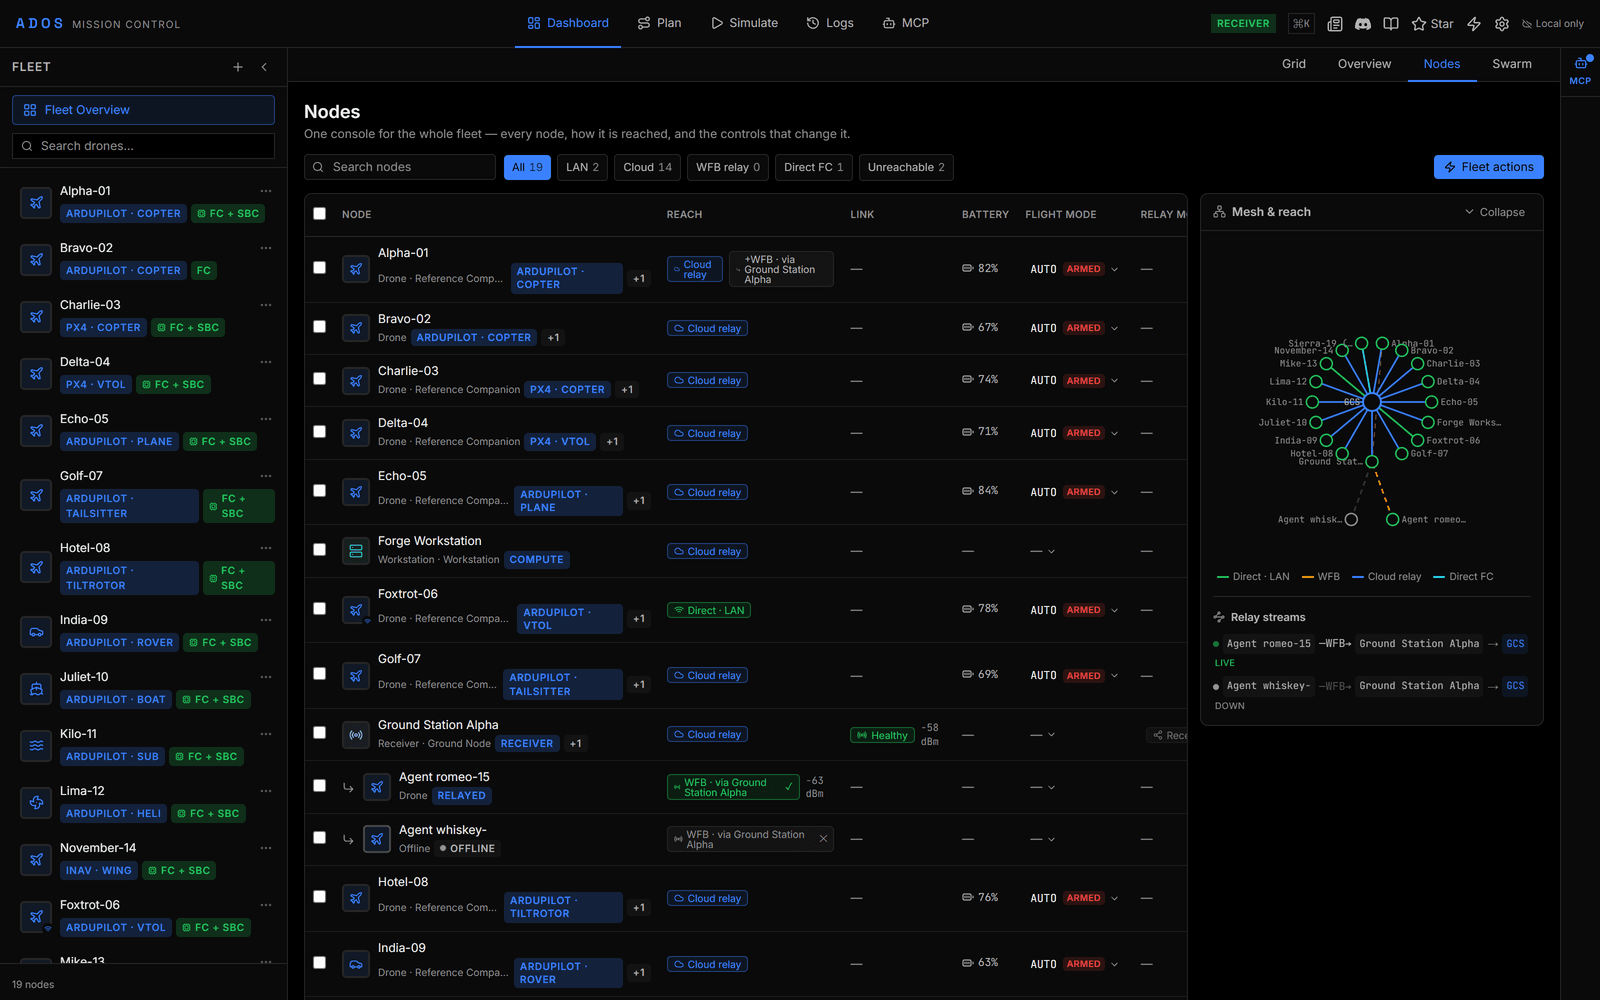
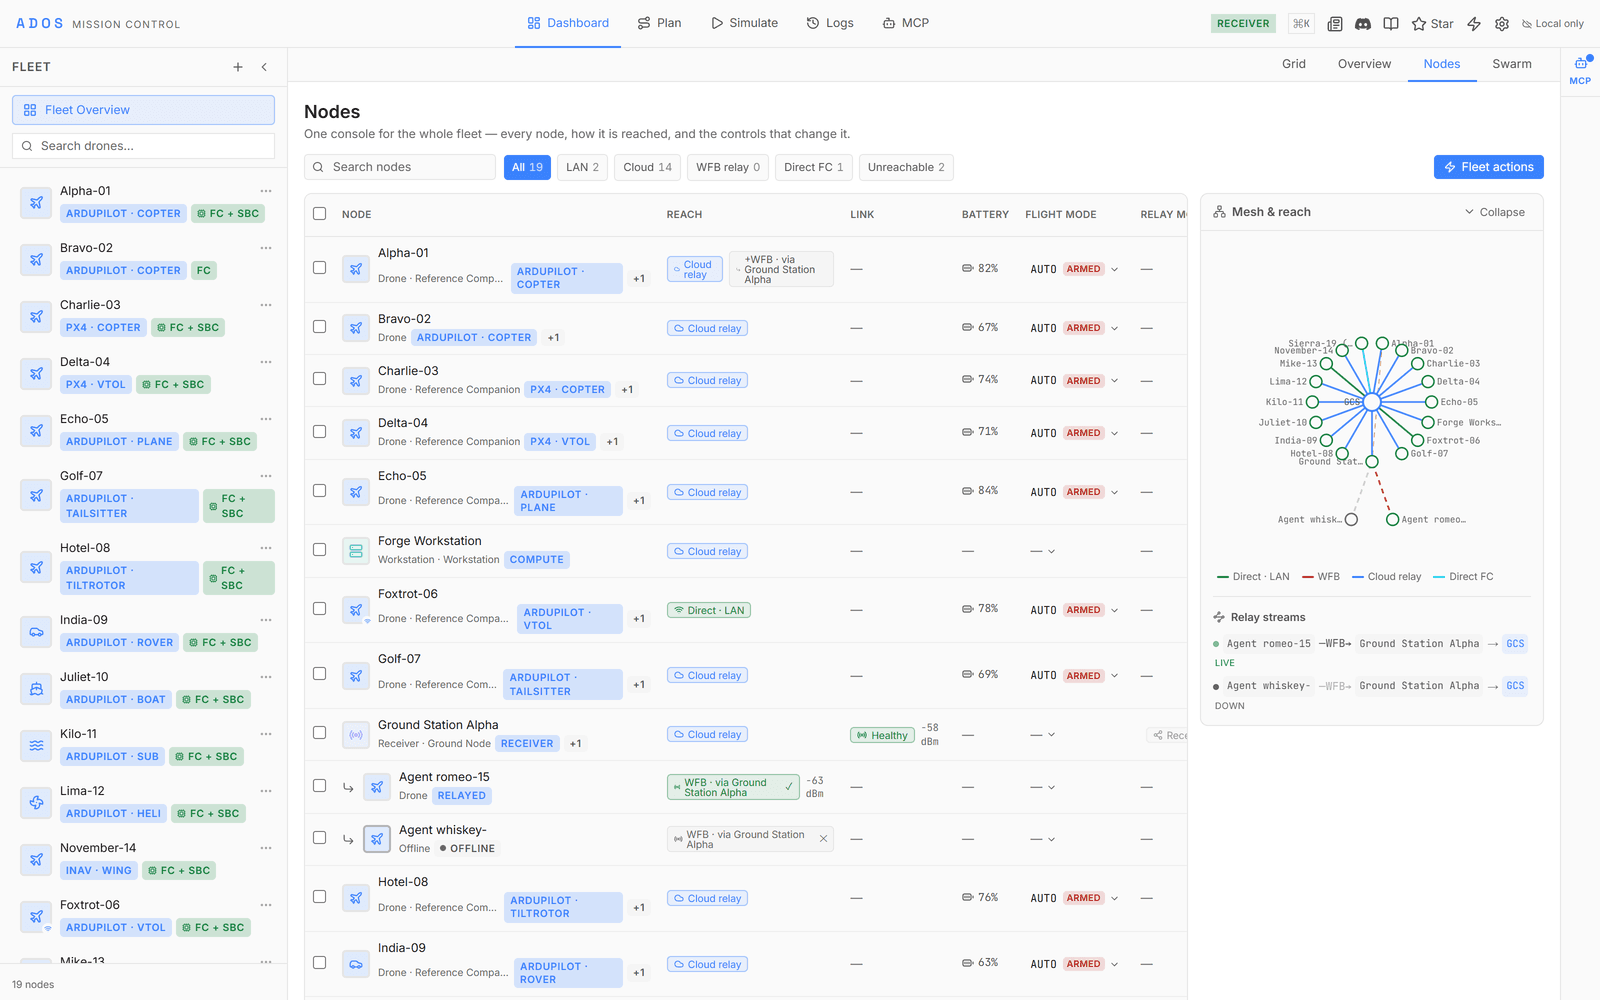
The console draws the fleet by how it connects. A ground station relaying to its linked drones reads as a branch, so a relayed drone sits under the node that carries it, not as one more equal dot in a row.
Nodes, grouped by how they connect
The fleet view lists every node with its reach path, so a relayed drone sits under the ground node that carries it.
One node, opened
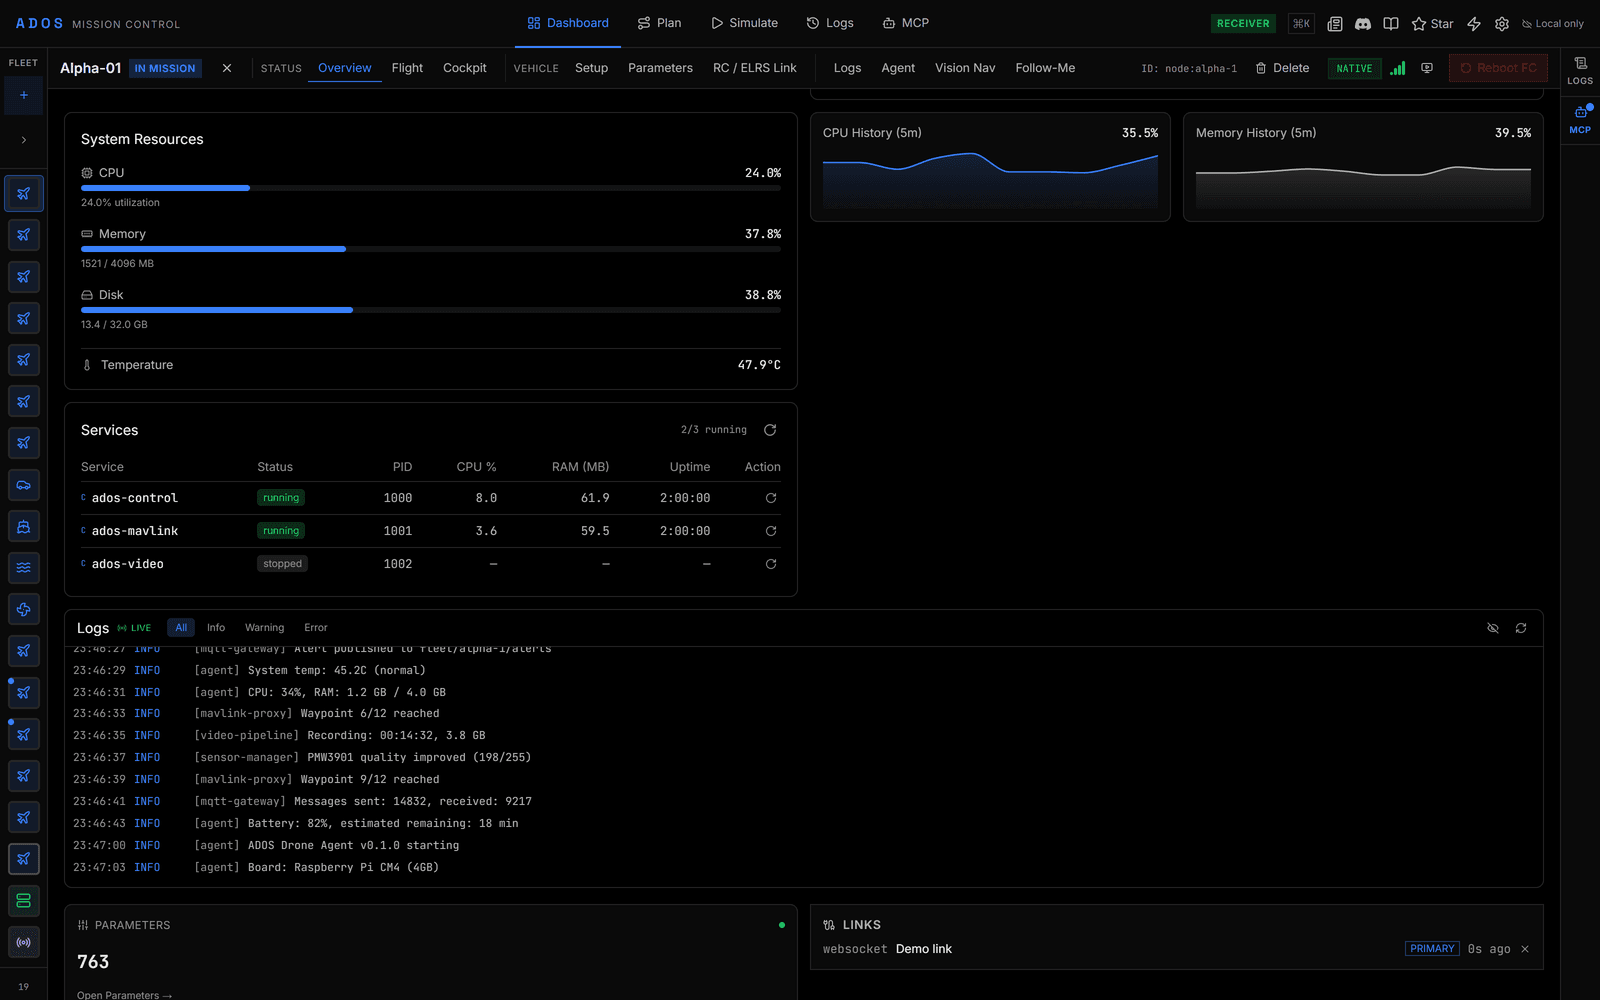
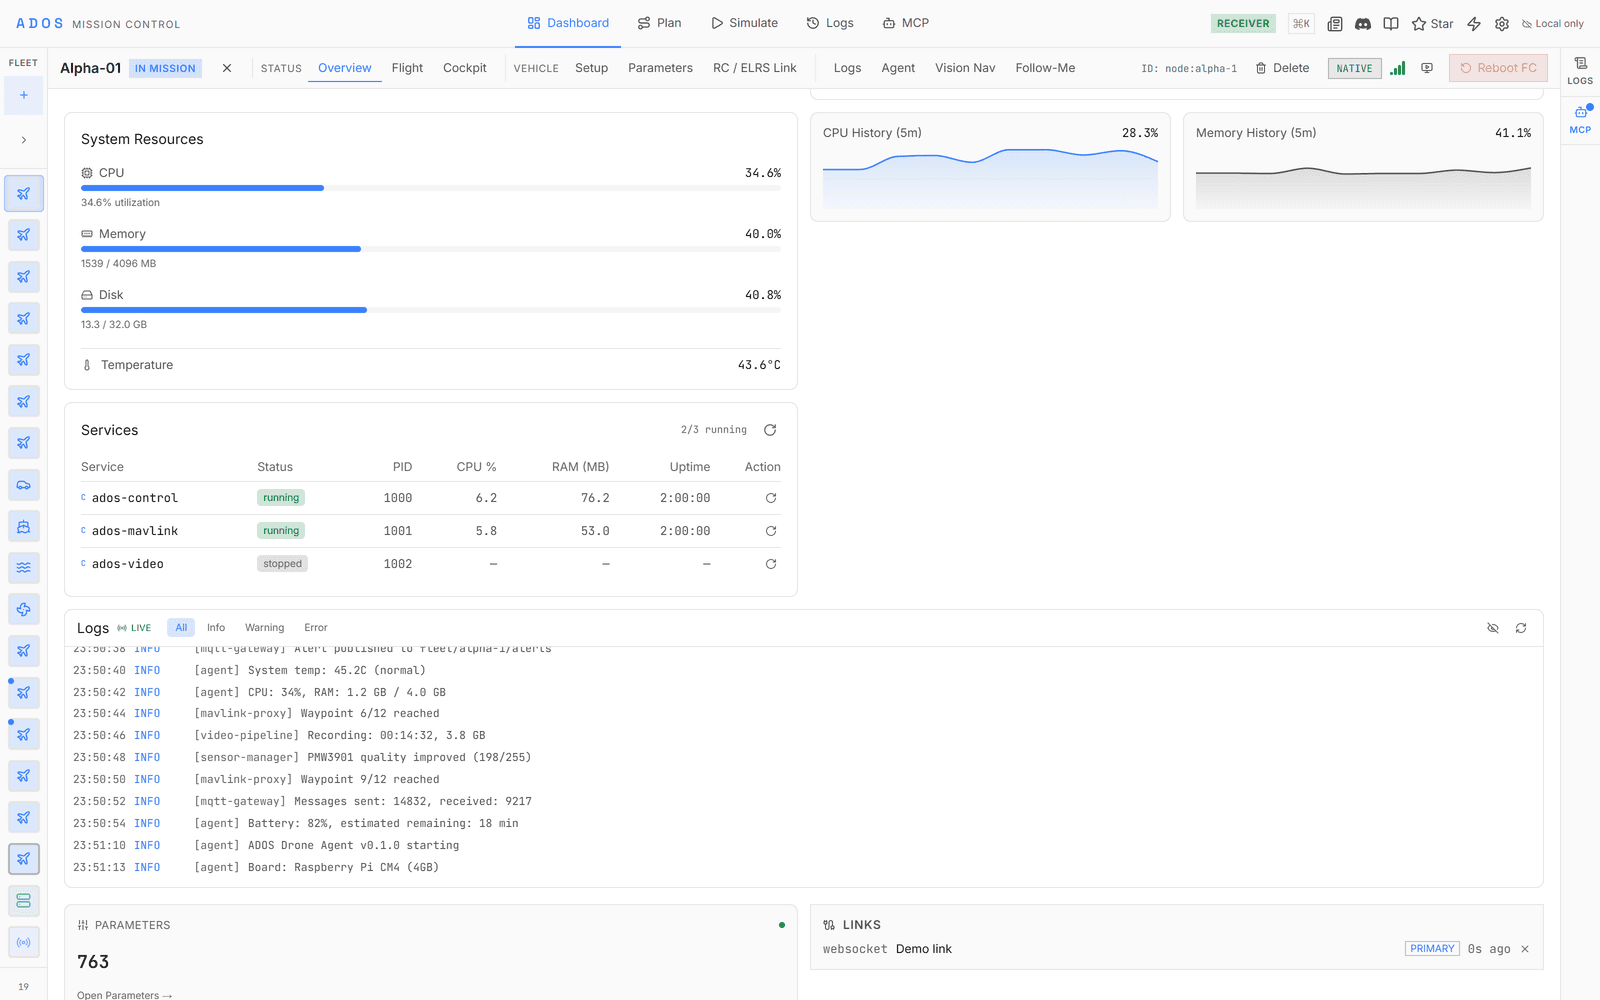
Open any node for its live state and the controls that write over its current path.
CONTROLS
Act on one node, a group, or the whole fleet.
Flight actions work at any scale, from a single node up to the entire fleet. Settings and mesh-role changes stay per node.
Return the whole fleet
Return all, from the header, sends every node home at once. It runs against each node over whatever bearer currently connects it and skips nodes that cannot fly an autonomous return.
Act on a single node
Open a node to set its flight mode, request a return, or restart a service. Flight commands go over whichever path reaches that node; a ground station's mesh role is set through its local agent.
Act on a selection
Select several nodes and apply one flight action across all of them. The bar says how many can take it before you confirm. Arming stays a per-node decision.
Every flight command writes over whichever bearer currently reaches the node, so a command to a drone on the local network and one over the cloud relay start from the same place in the console. Over the cloud the console shows a delivery receipt, not the vehicle's own acknowledgement.
See the whole fleet, act on any of it.
Fleet management runs inside the open-source Mission Control. Read the code and run it yourself.
Mission Control on GitHub