Your drone is a relay too.


The aircraft can carry the link, not only ride it.
REACHED THROUGH A RELAY
Linked over the radio, still its own node.
When the console pairs to a ground node, the drone linked to it over the radio joins the fleet on its own. It carries its own feed and a badge for how it is reached, so it reads as a real node rather than a stream hidden behind the ground station.
Every node states how it is reached: a reach label in the node header, a relayed badge in the fleet sidebar, and a hover card with the health of each hop, from the ground station to the console and over the radio.
Identity is keyed to the drone, not to the path. Reach it later on the same network and the console upgrades the existing node in place rather than spawning a duplicate. One drone stays one node however you get to it.
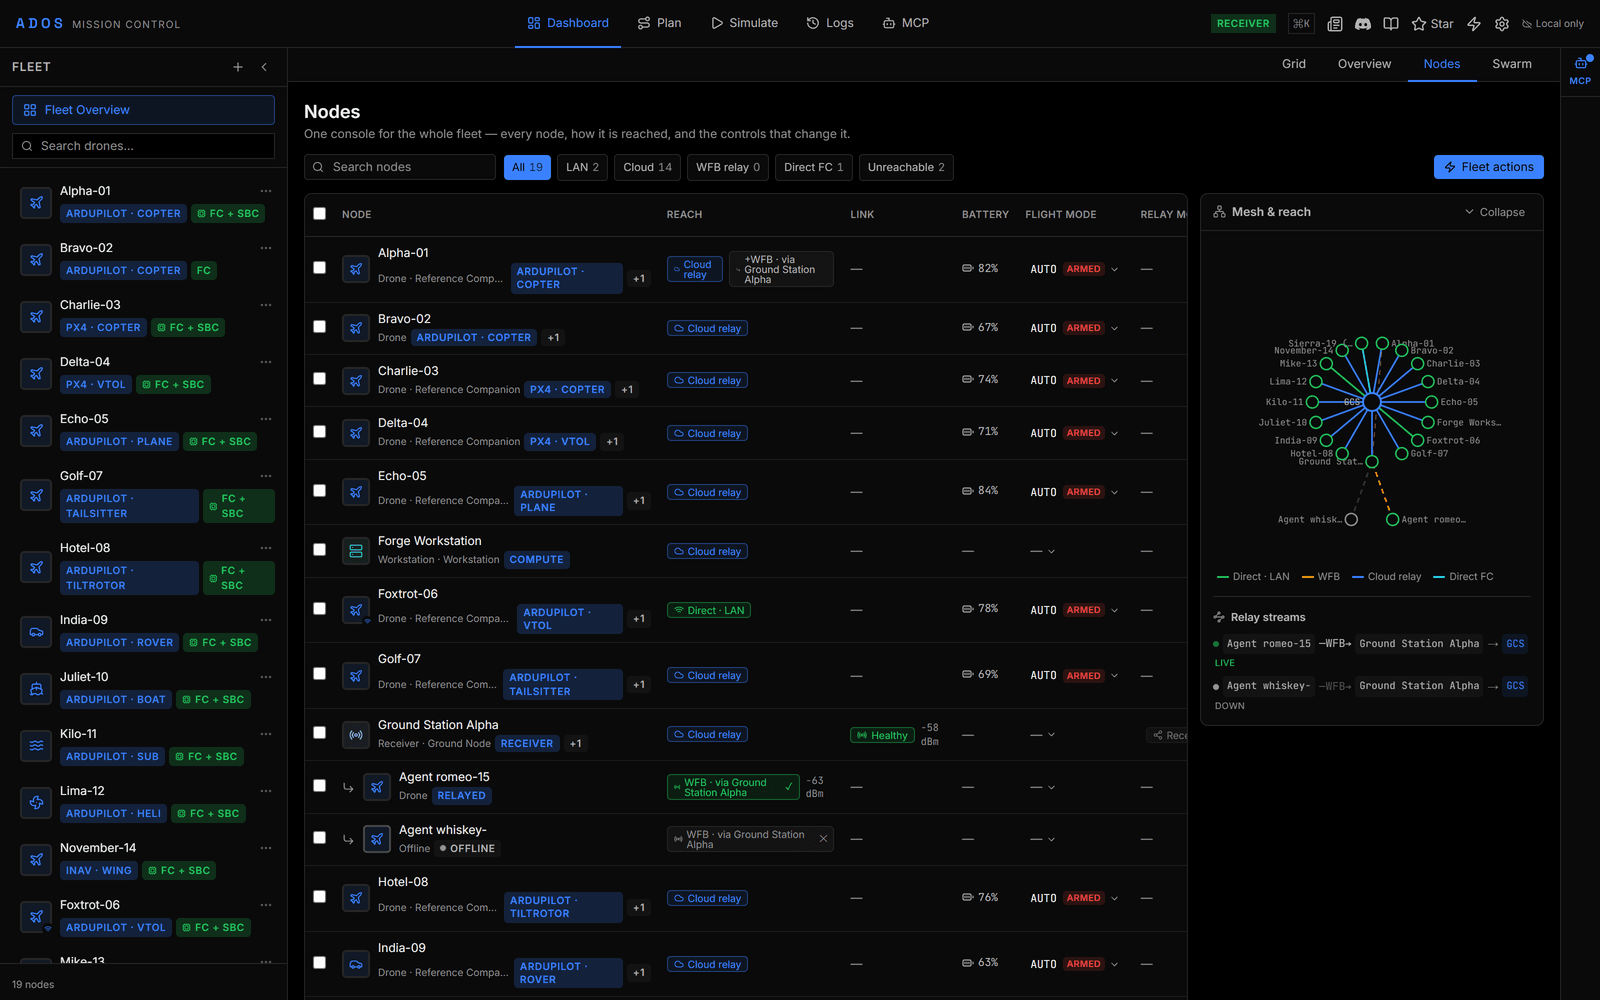
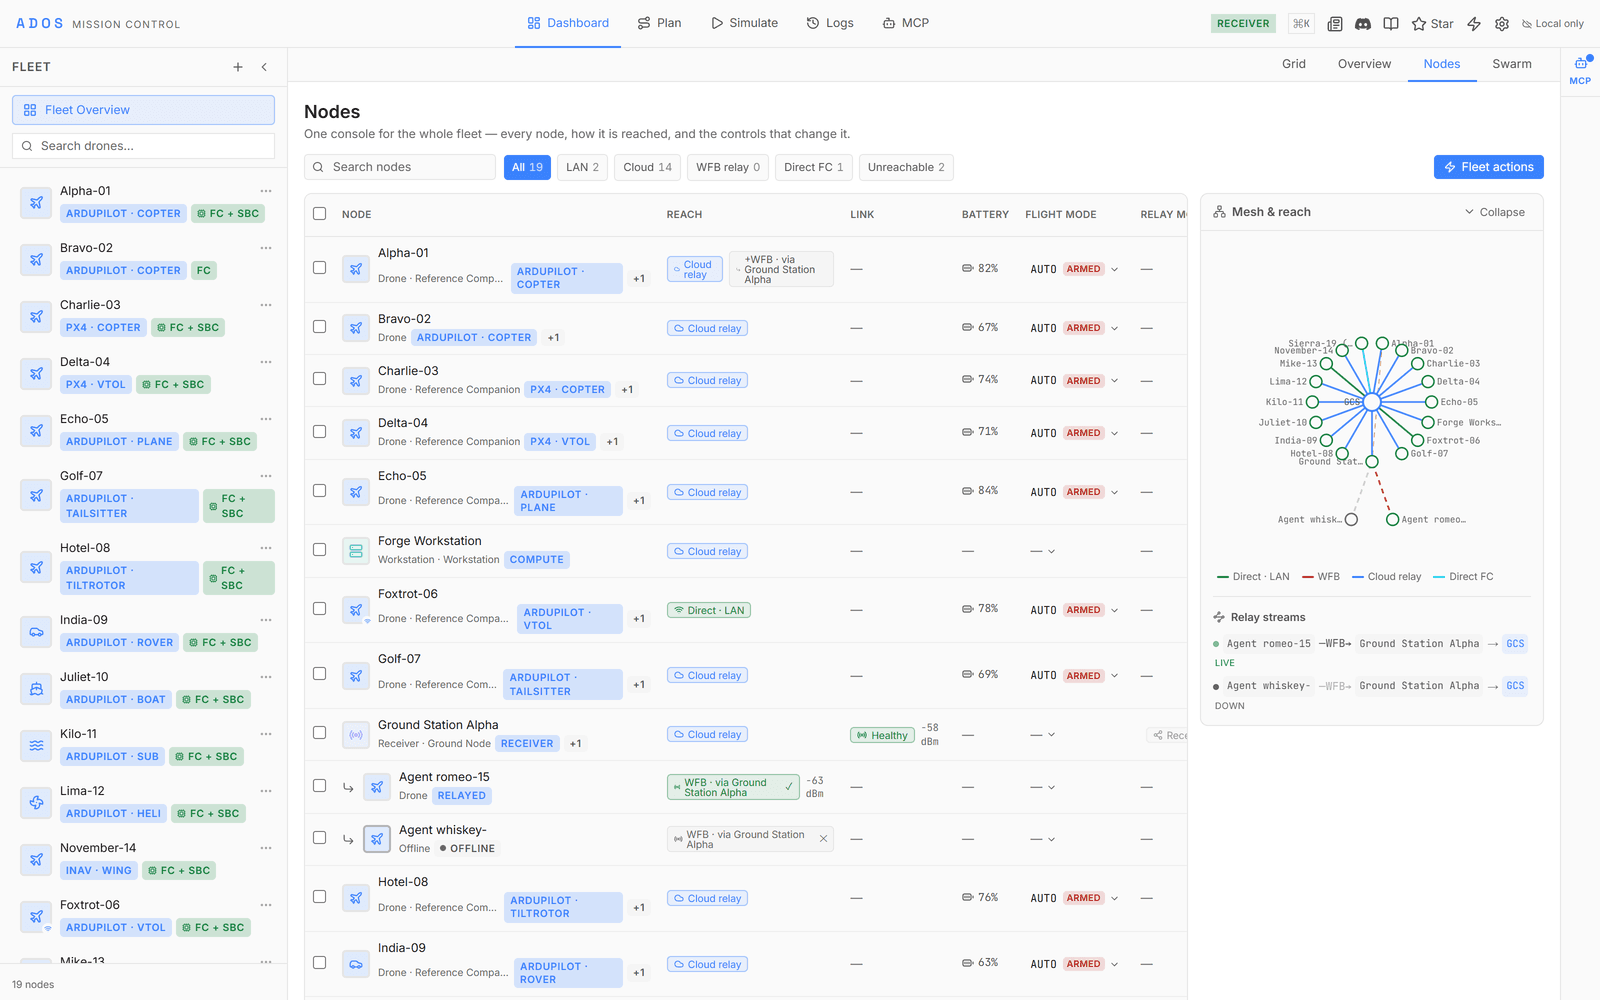
A HOP FOR ANOTHER DRONE
The drone can carry the link, not just ride it.
Reach is bounded by what an antenna can see. A drone with a second radio can catch a farther drone and forward its stream over a self-healing mesh, so a target past the horizon can be reached through one that is closer. If a hop drops, the mesh re-routes with no operator action.
The relay roles and the self-healing mesh are the same ones the ground nodes use, covered in depth on the Distributed Receive page. The agent is one build, so the drone, the ground node, and the relay in between all run it.
THE CONTROL LANE
A command path that is not the video link.
Alongside the main radio, a low-bandwidth control lane over ELRS carries commands and light telemetry on its own path. It is the backup for the moments that matter: flying the drone home when the main link is stressed, or reaching a small drone that carries no companion computer at all.
The drone receives plain RC channels or a MAVLink command and telemetry stream over the lane, whichever the flight controller speaks. Because it rides its own radio, it stays up as a path back when the main link struggles.
Command authority is arbitrated, so the main link, the lane, and a failsafe never fight for the vehicle. The full command path over the lane is off by default and needs explicit enablement; telemetry over the lane works without it.
The ground node drives this lane as a programmatic transmitter. Its full setup, the lane modes, and the relay-to-another-drone path are on the ground node's Relay and Control page.
THE DRONE'S ROLES
Reached, relaying, or flown on the backup.
The same agent lets a drone be found through a relay, carry another drone's link, and keep a command path open, all without a change of software.
Reached
Flown through a relay
The drone can be reached and flown through a ground node or a nearer drone. Its link rides the relay while it stays its own node in the fleet.
Relaying
A hop for another drone
With a second radio the drone can carry a farther drone's stream and telemetry, extending reach past what a single line of sight covers.
Backup
A separate command path
A low-bandwidth control lane rides its own radio, so there is a way to fly the drone home when the main video link is stressed.
Last mile
Reach a bare drone
A small drone that carries no companion computer can still be reached over the control lane as the last hop, through a node that does.
RELATED
Take it further.
One agent. On the drone and on the relay.
The same agent runs on the drone, the ground node, and the relay in between. Read the reach model and the control-lane reference in the public docs.
Transitive enrollment docs